For your own hardware
For machine and device makers who design their own board. You get the prebuilt library for ESP32 and STM32, a demo project and the EtherCAT Configurator, with a licence per device. Your electronics, your enclosure, our master.
EtherCAT master on a microcontroller: as a library or as a ready controller
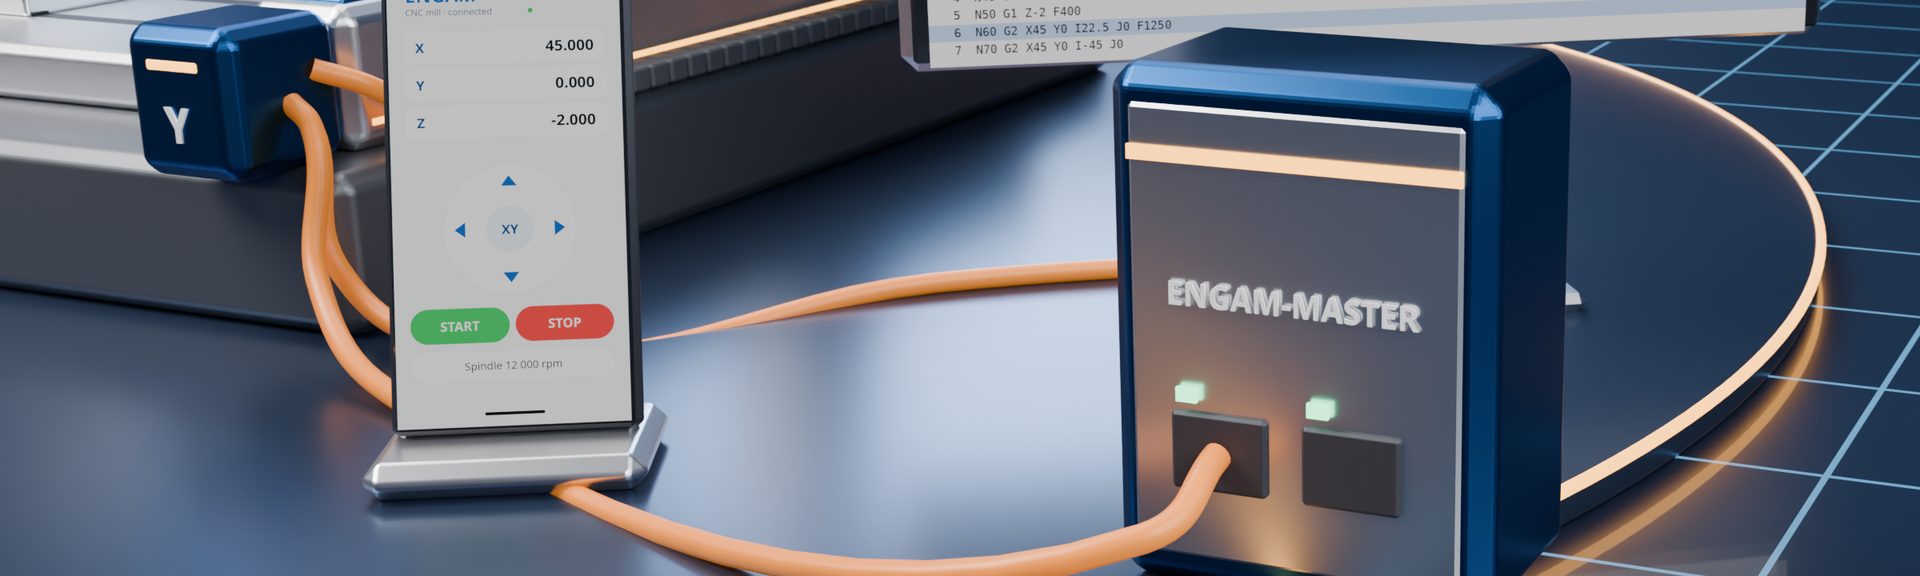
ENGAM-MASTER turns an ESP32 or STM32 board into an EtherCAT master. It drives servo and stepper drives over a single Ethernet cable, with Distributed Clocks and CiA 402 motion, and gives machine builders a compact controller without an industrial PC. Use it as a library on your own board, or take the ready controller and mount it in the cabinet.
Library or controller
Whether you build your own electronics or need a controller in the cabinet tomorrow, ENGAM-MASTER fits: the same EtherCAT master, the same configurator and the same motion API in both forms.
For machine and device makers who design their own board. You get the prebuilt library for ESP32 and STM32, a demo project and the EtherCAT Configurator, with a licence per device. Your electronics, your enclosure, our master.
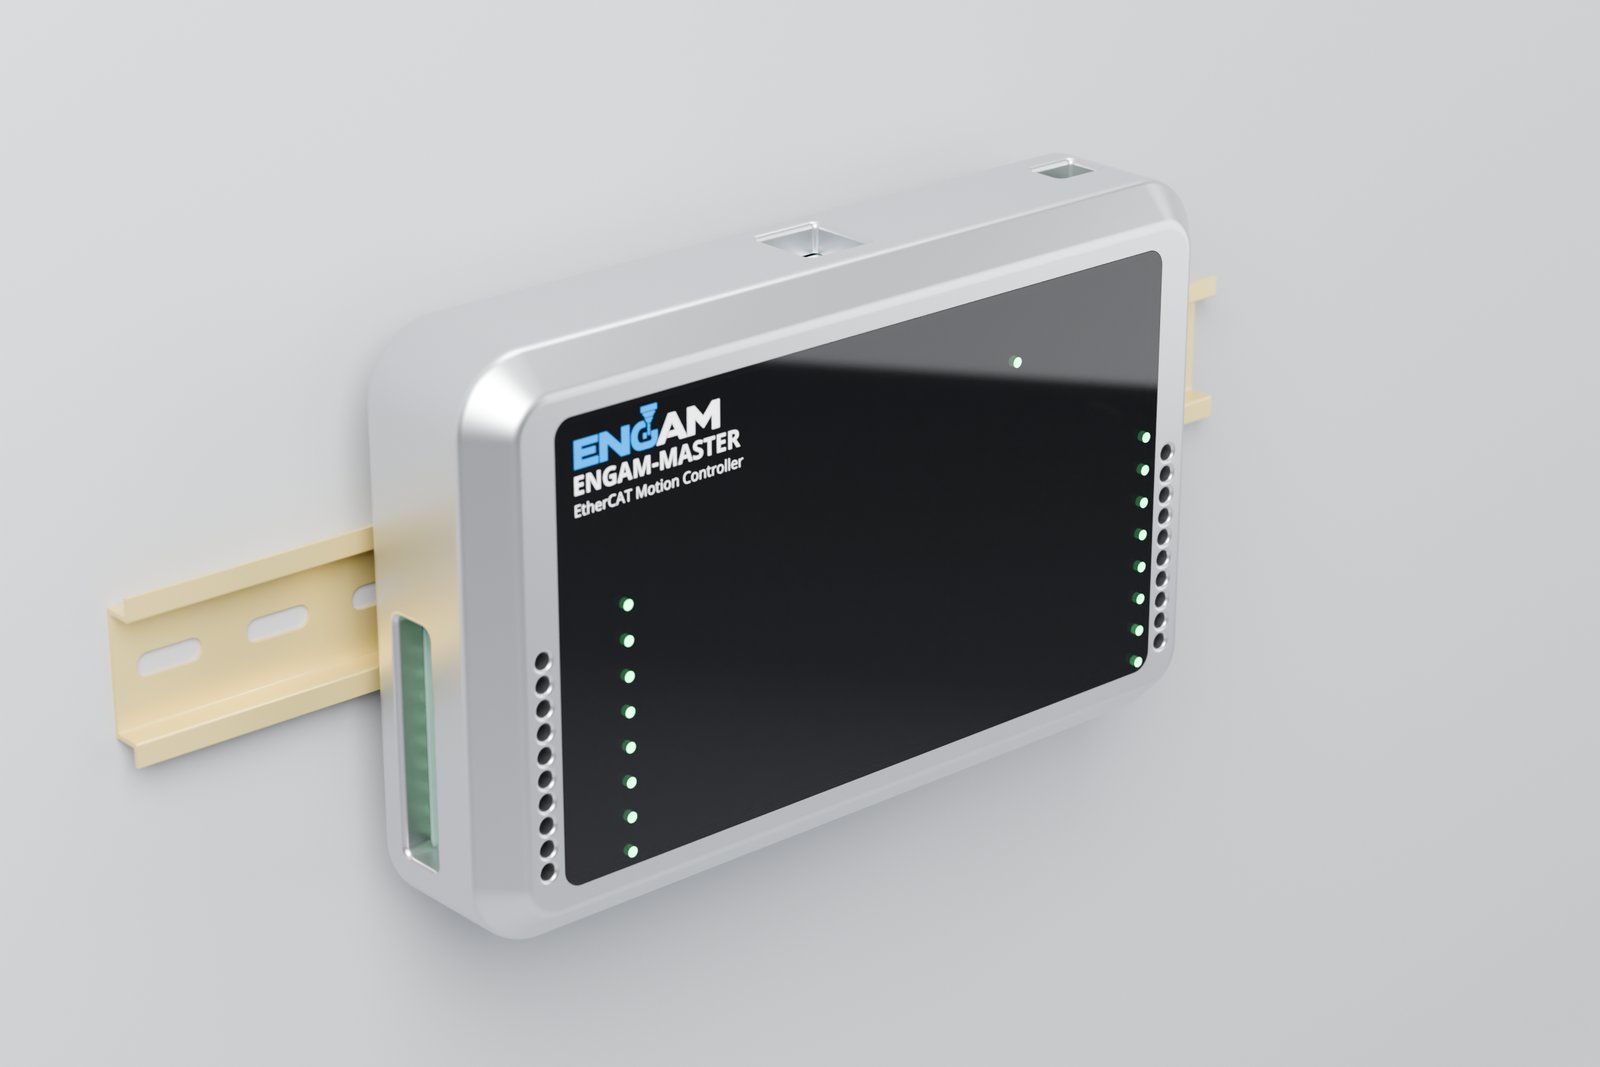
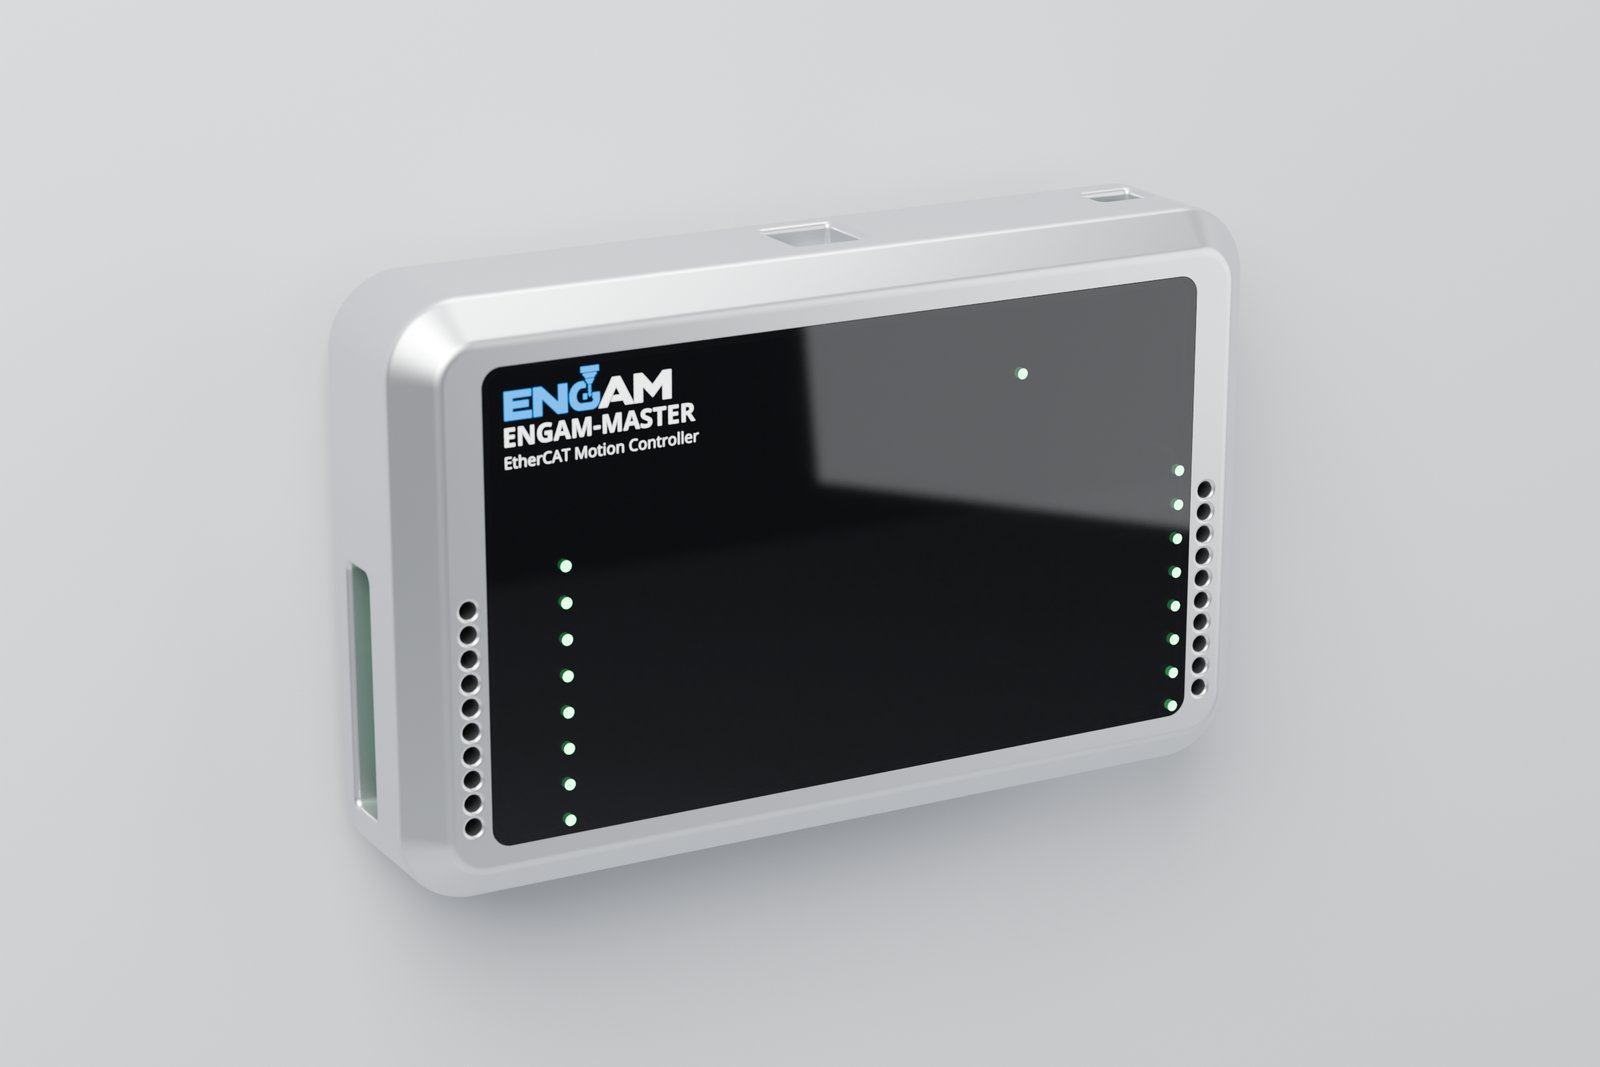
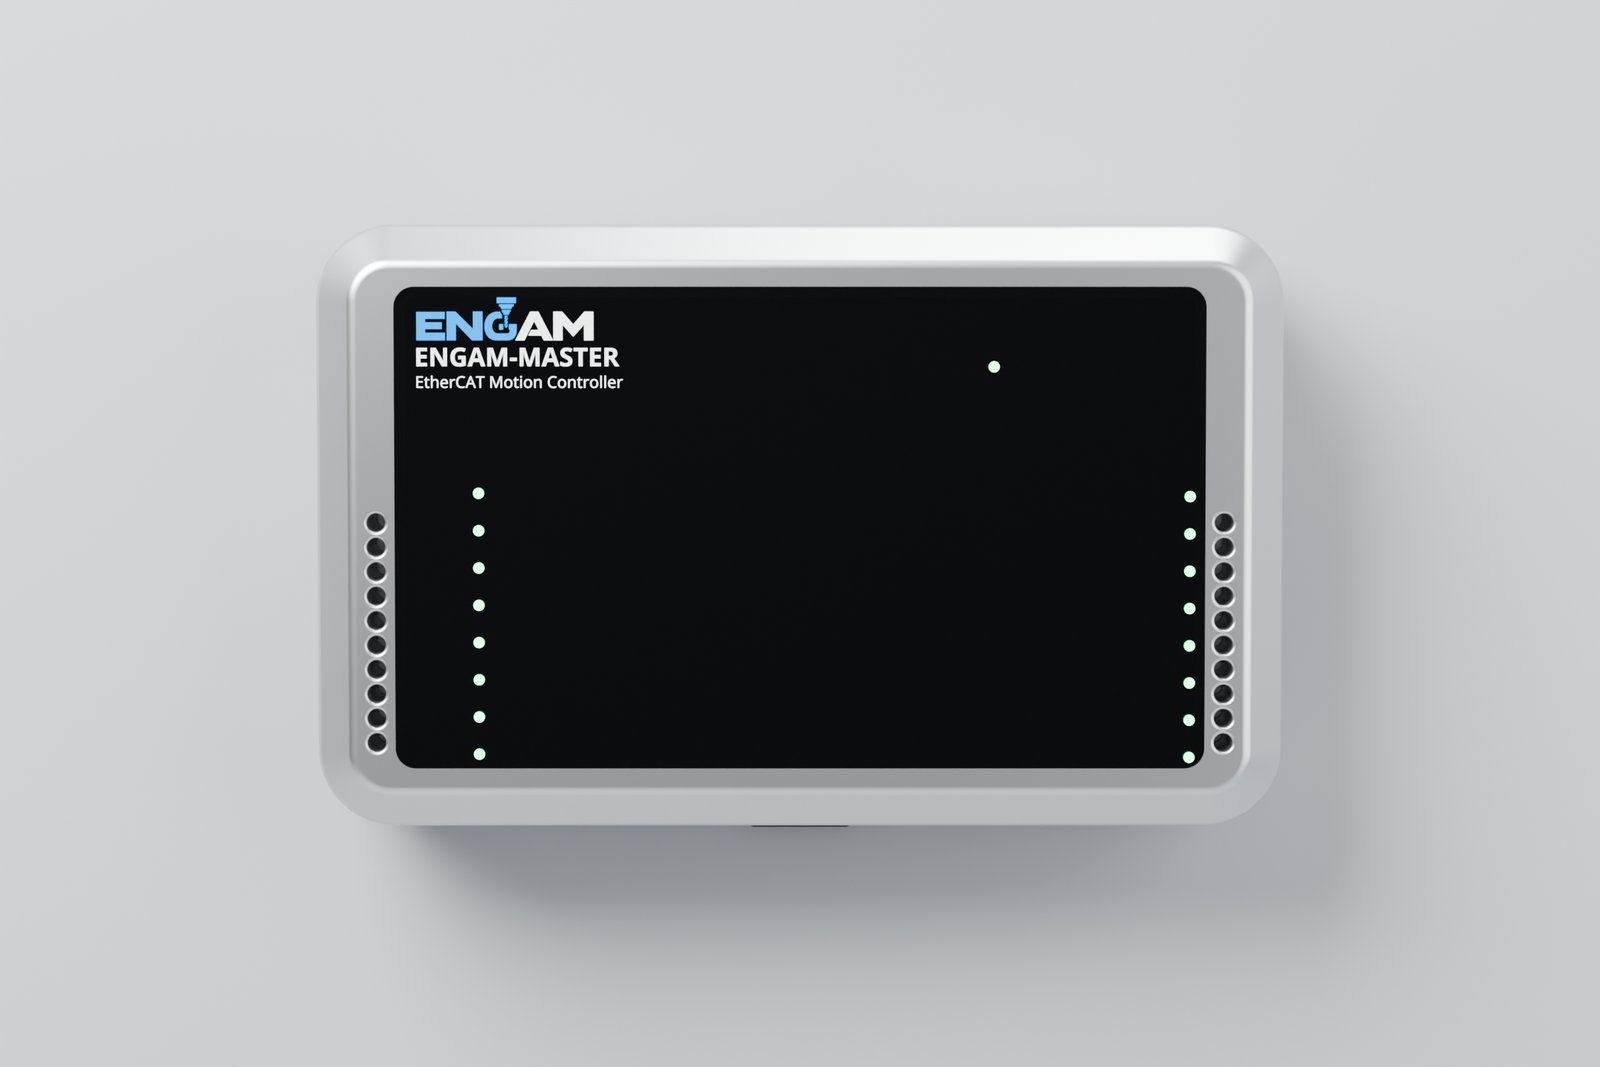
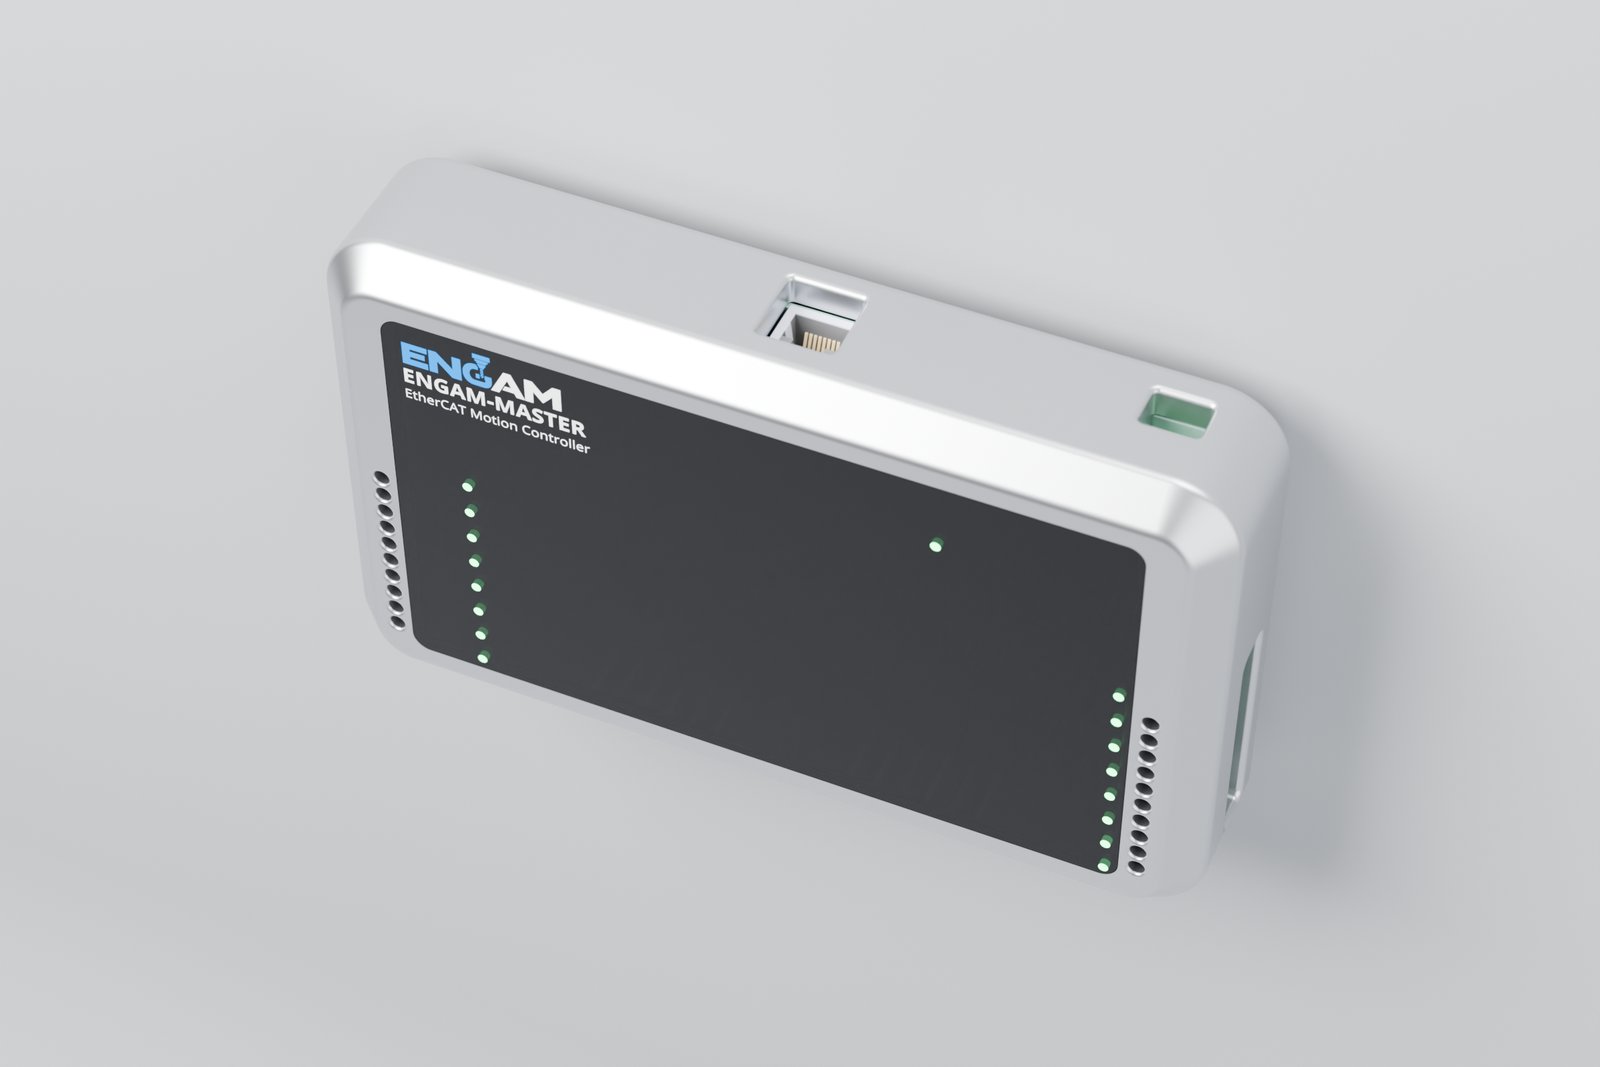
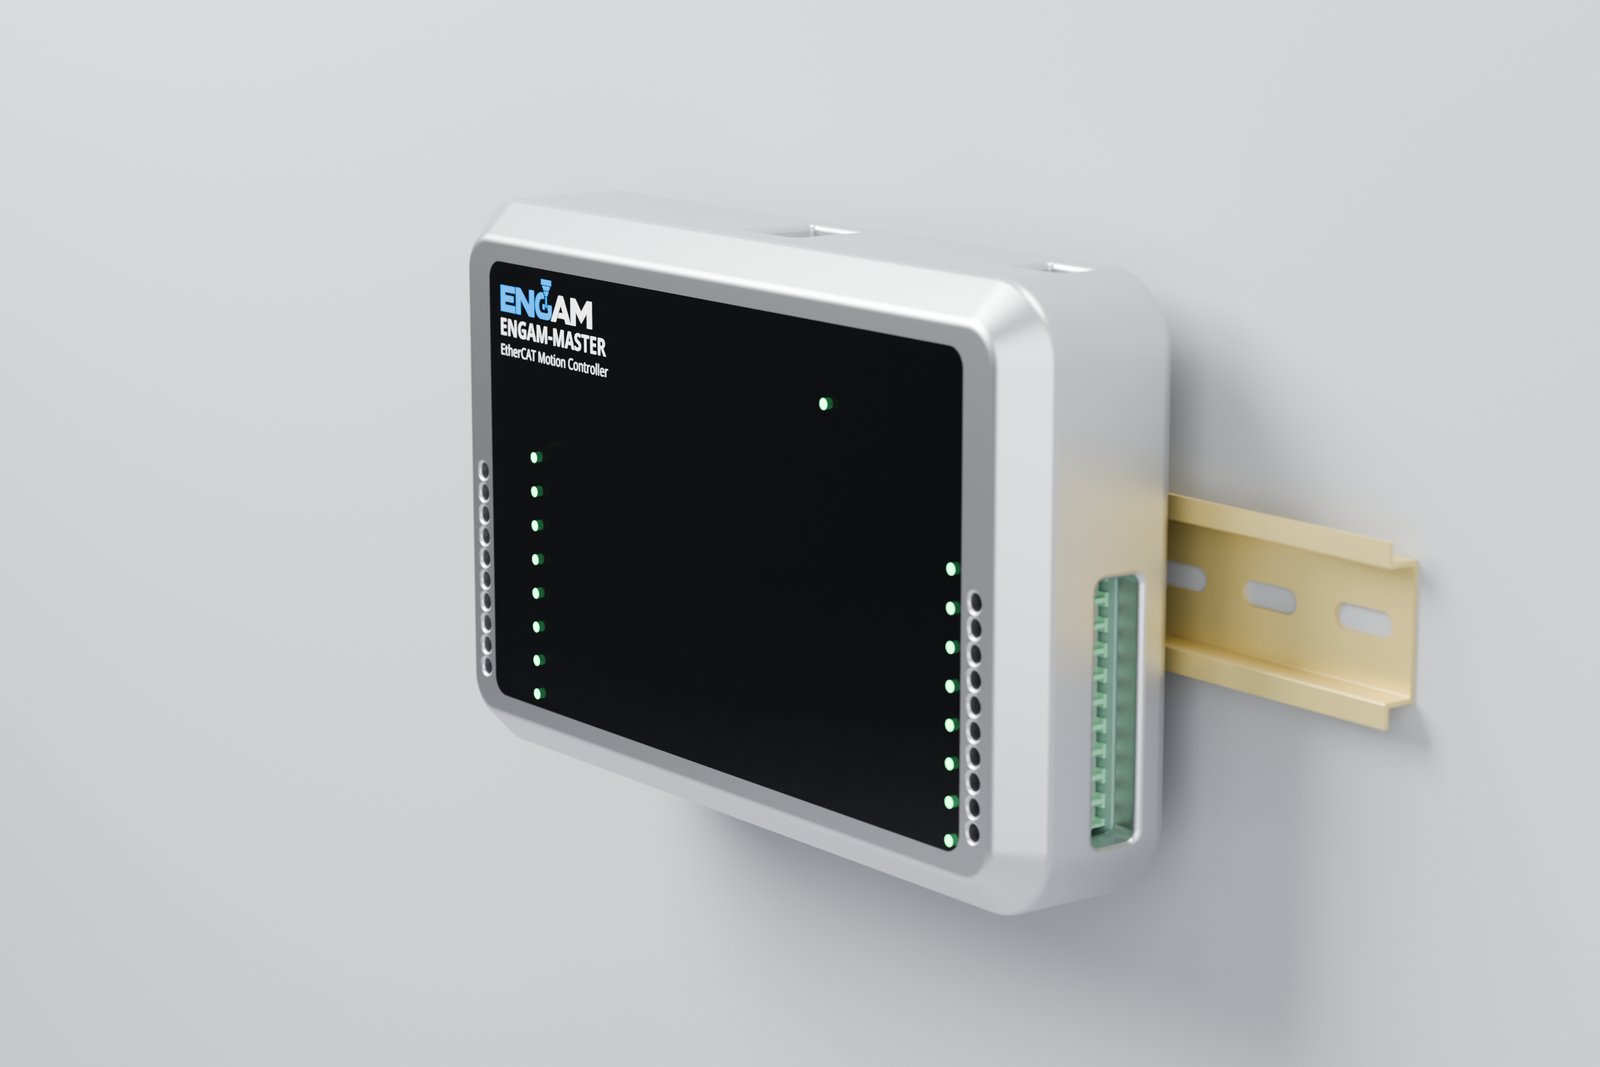
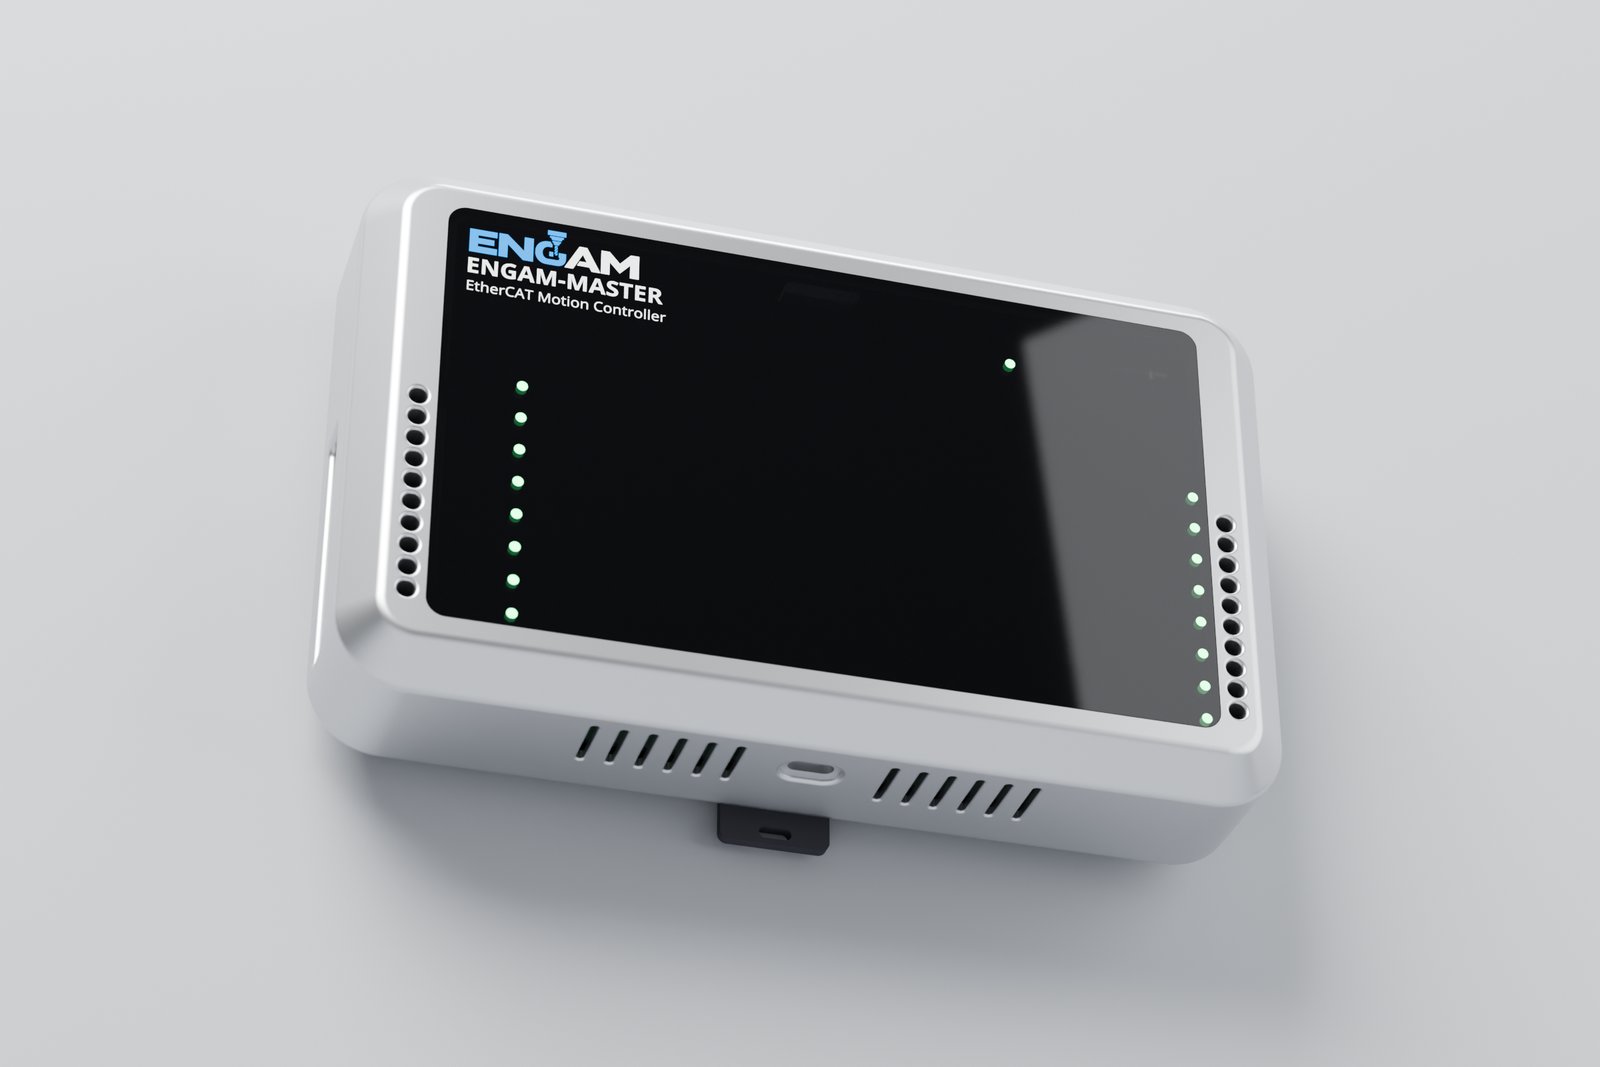
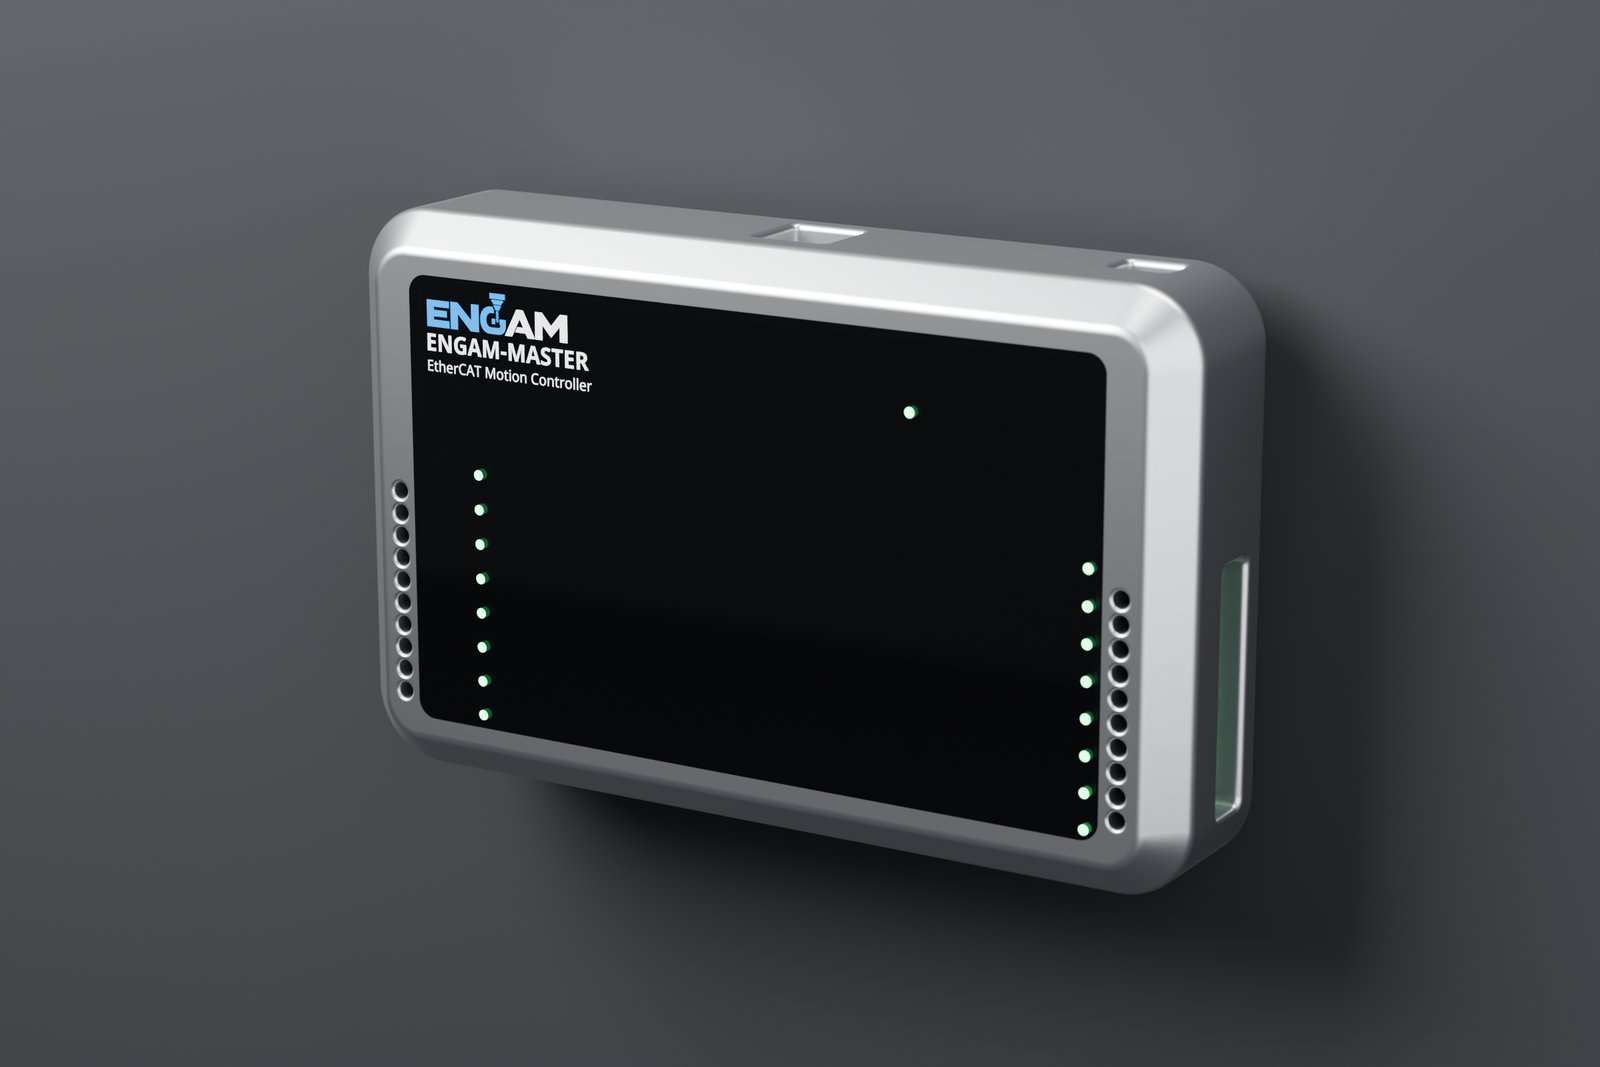
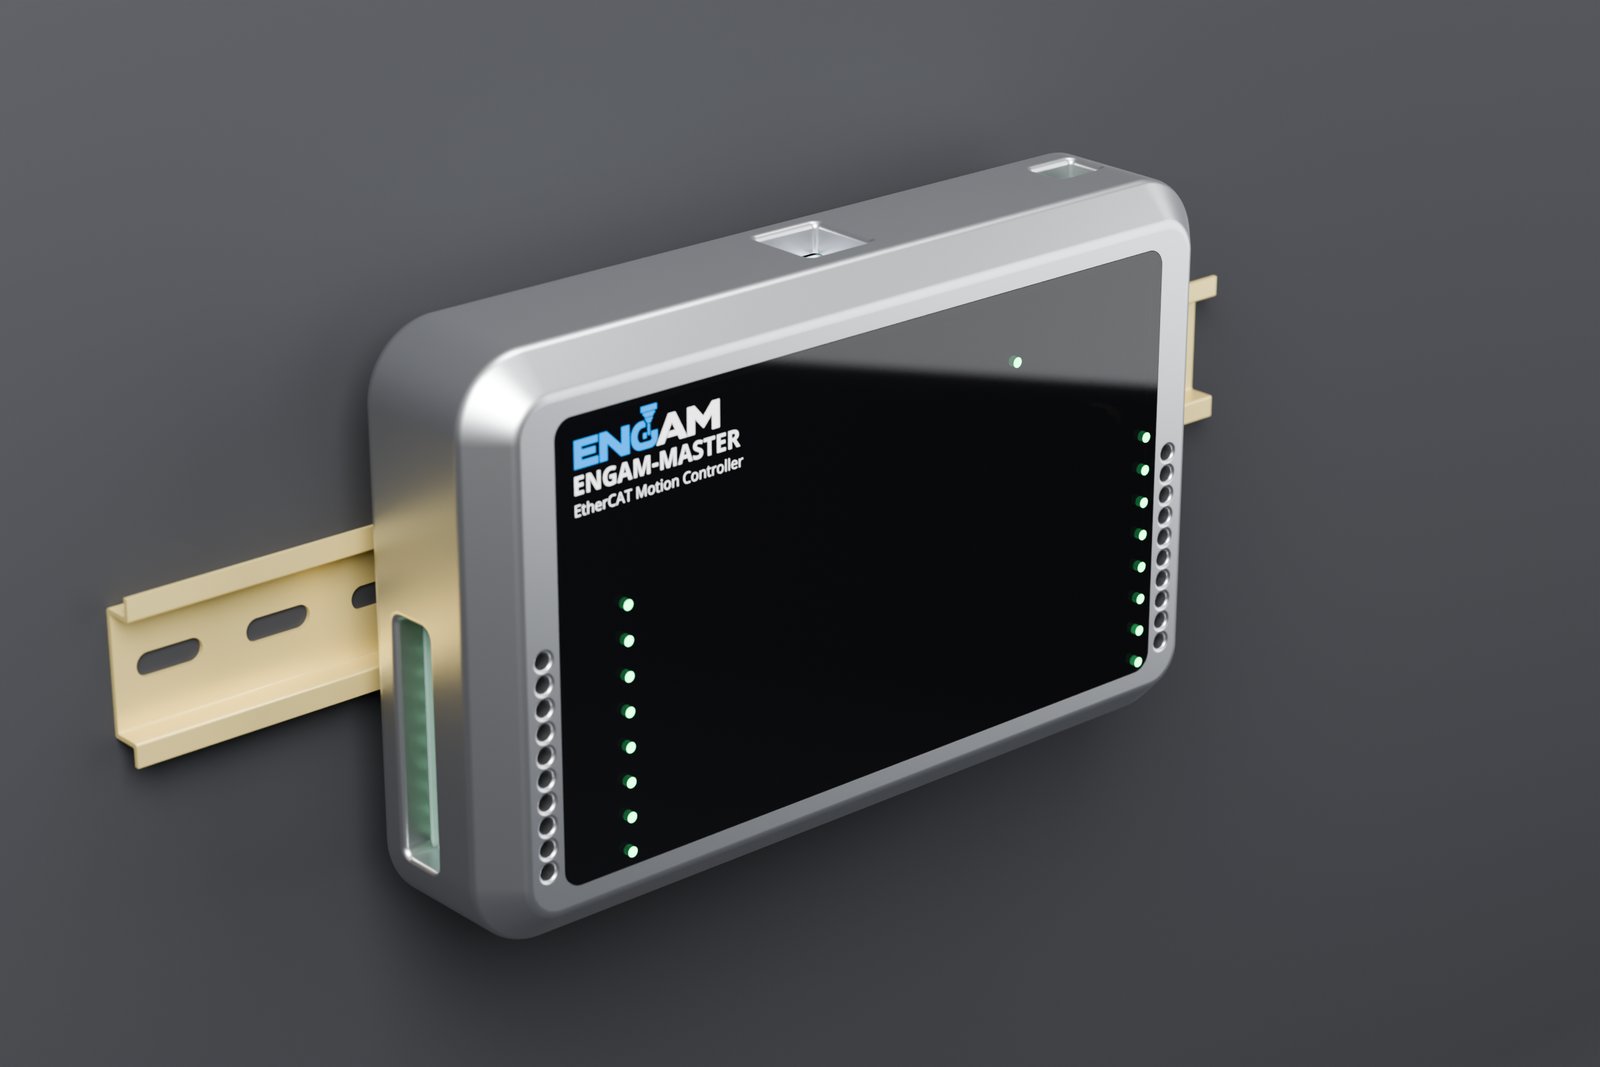
For machine builders, workshops and retrofits that need a working controller now. Aluminium enclosure, 24 V supply, 8 isolated inputs and 8 outputs, EtherCAT and USB-C. Mount it on a DIN rail or on the wall, connect the drives and program the machine.
Start with the ready controller and move to your own board as the series grows: your machine code carries over.
Specifications
Tested with Lichuan LC10E servo drives. Other CiA 402 drives can be added from their ESI file.
Ready controller
Two mounting options: snap it onto a standard TH35 DIN rail in the cabinet, or hang it on the wall with four keyhole slots on the back, like a Wi-Fi router.
ESP32 version
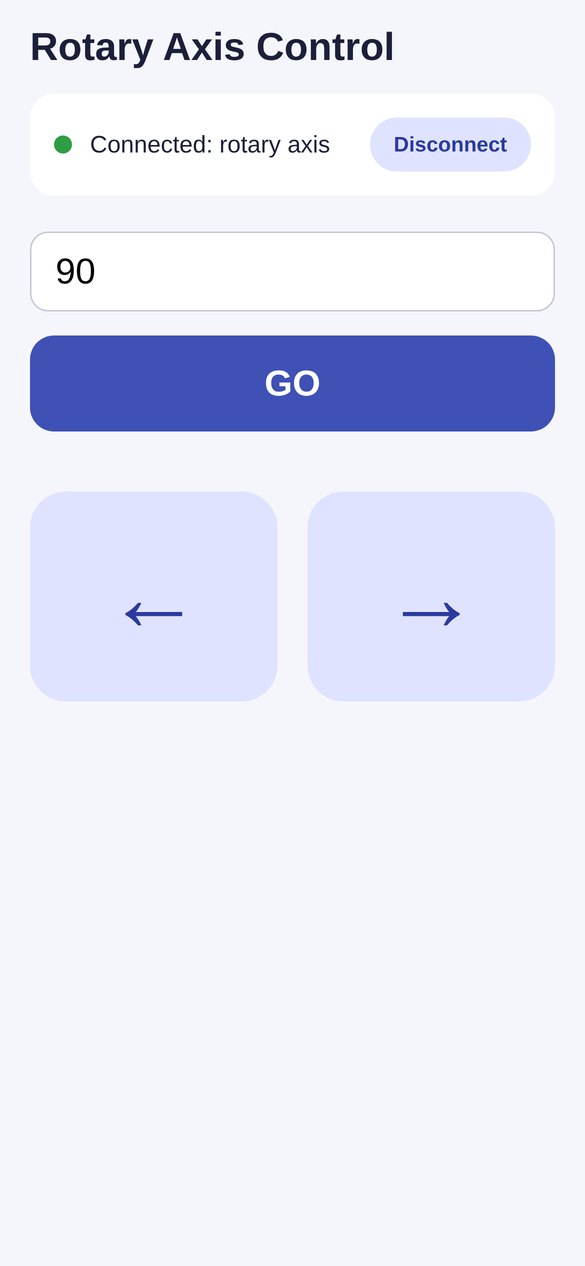
The ESP32 version keeps the chip's own wireless connections free for your machine: Wi-Fi and Bluetooth can be used to control and monitor the master remotely, from any phone, tablet or laptop, while EtherCAT runs on the wired Ethernet port.
Example
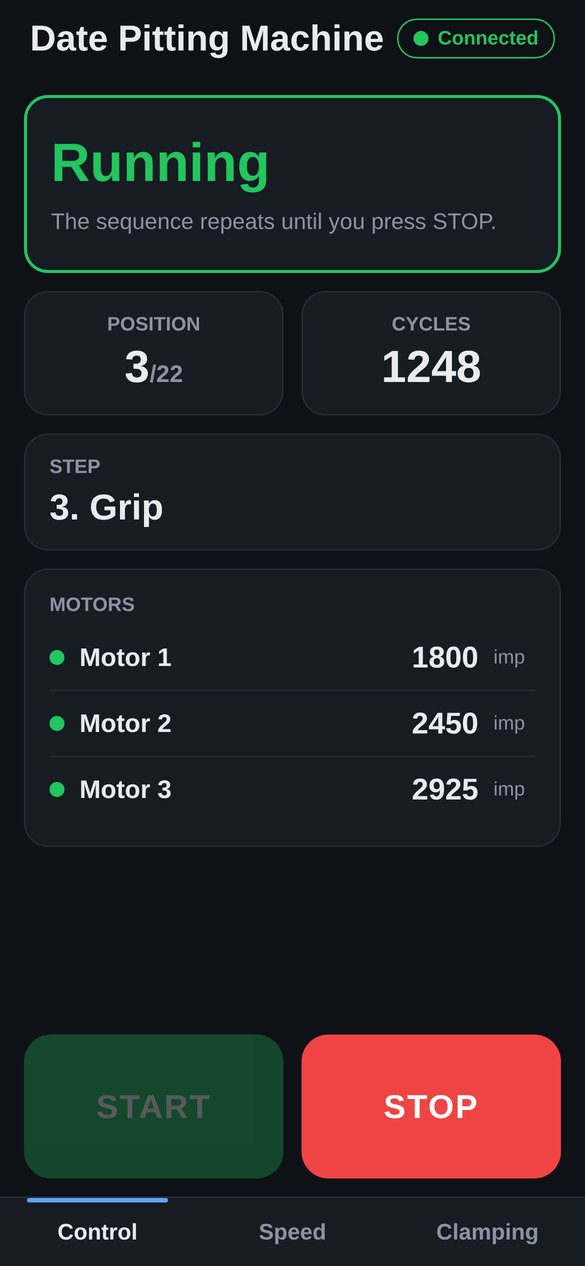
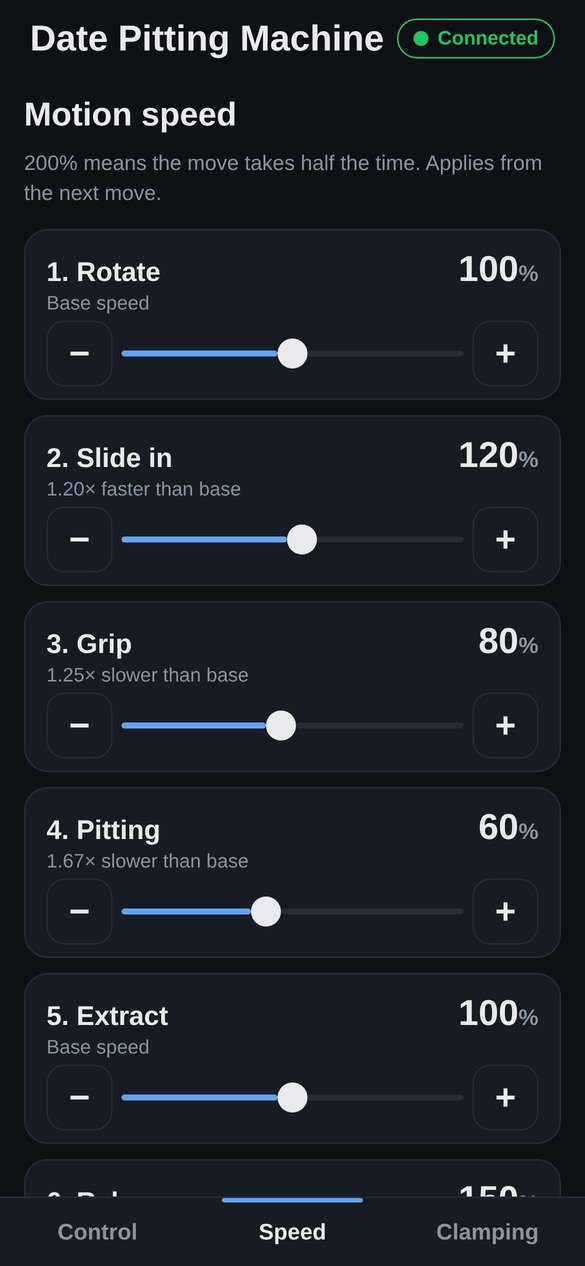
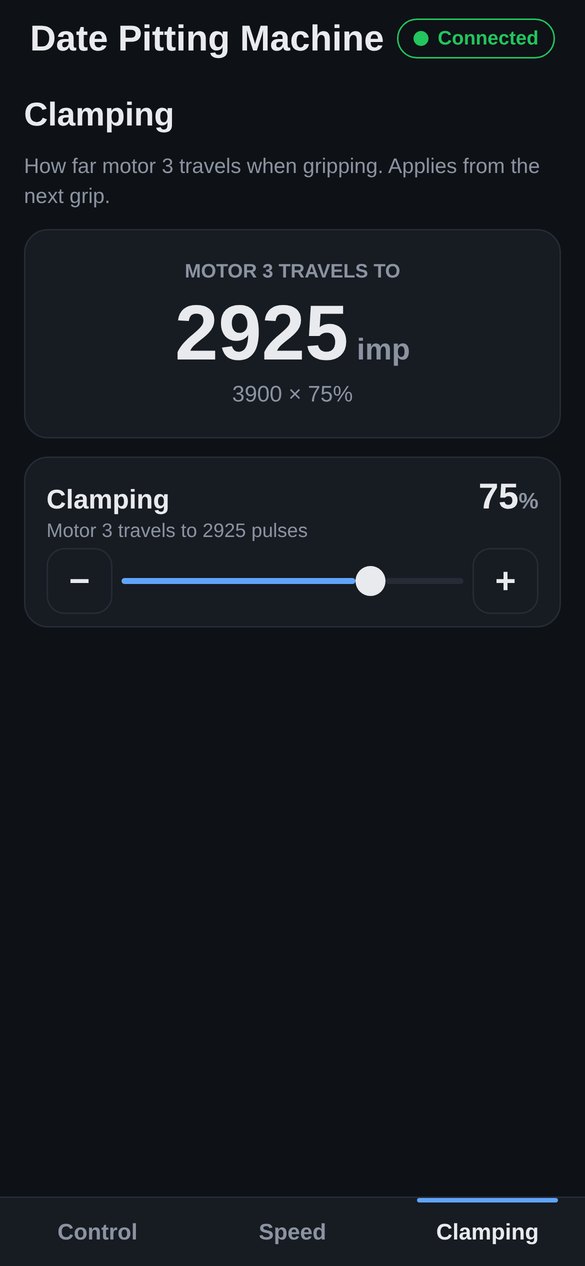
An ESP32 with ENGAM-MASTER drives three Lichuan servo motors over EtherCAT and runs the machine sequence. The phone connects over Bluetooth: start and stop, live status of every motor, the speed of each step and the clamping are set from the app.
Tools
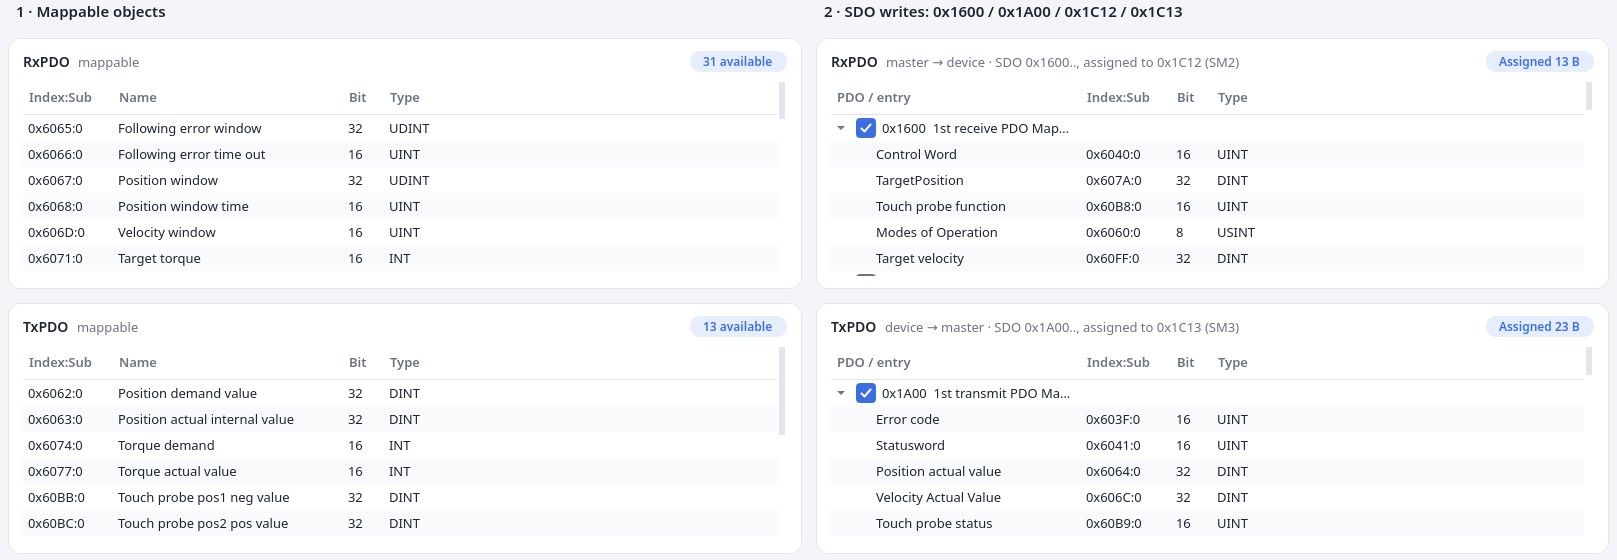
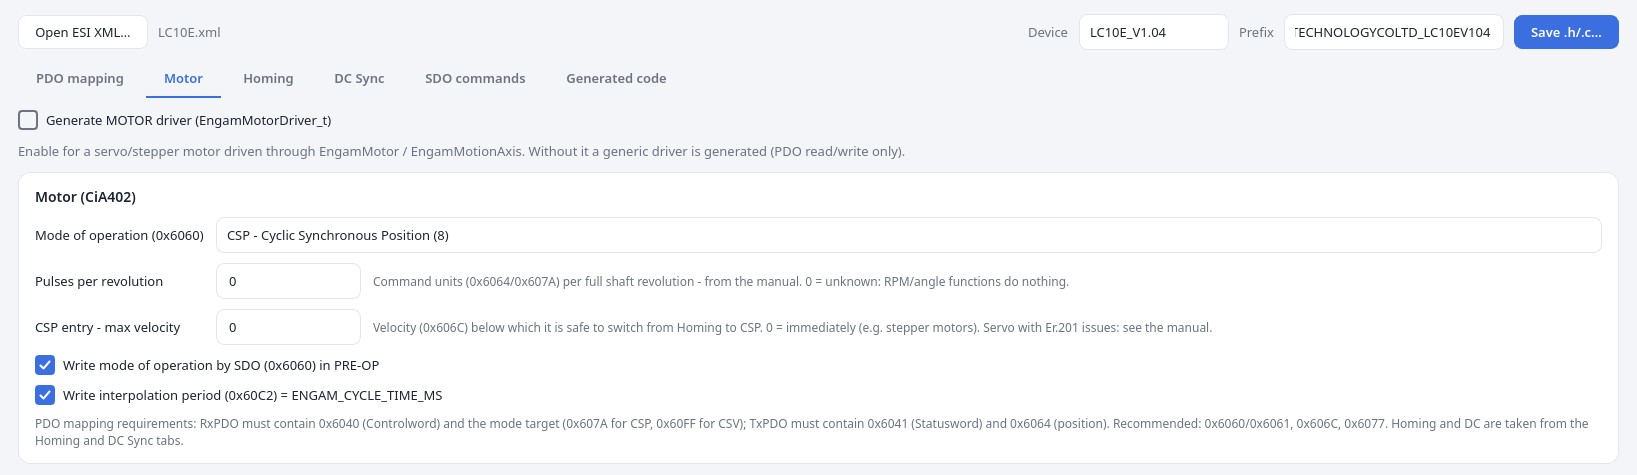
Open the ESI file you received from the drive or I/O maker and the configurator prepares the device for ENGAM-MASTER. No hand-written PDO tables.
Industry 4.0 ready
A machine with ENGAM-MASTER is connected, transparent and easy to change: the foundations of Industry 4.0, built into the controller.
EtherCAT on the wired port for the drives, Wi-Fi and Bluetooth for people and systems. The machine is on your network from day one.
Position, velocity, status and errors of every drive and the state of every input and output, read in every bus cycle. The basis for monitoring, diagnostics and maintenance planning.
Start, stop, settings and live status from a phone, tablet or laptop, in the browser or in an app, without special software.
EtherCAT, the CiA 402 drive profile and ESI device files: drives and I/O from different makers work on the same bus, with no vendor lock-in.
A new drive is added from its ESI file in the configurator, the cycle time is set at start-up and new software goes in over USB-C. The machine follows the product, not the other way round.
Machine logic stays in your own code, so the data can be passed on over the network to the systems you already use for production planning and reporting.
A low-cost microcontroller is the EtherCAT master. Smaller cabinet, lower cost, faster start-up.
A dedicated high-priority EtherCAT task on FreeRTOS, separated from motion logic and logging, so the bus cycle stays steady.
Communication watchdog: if the bus or a drive drops out, the axes are brought to a safe state.
The master is a closed library; your machine logic stays in your own code and is easy to change.
Delivery
A Linux / Raspberry Pi version is in development.
Early access
We are working with first users. Tell us about your machine and drives and we will send you the demo, or an offer for the ready controller.
Our engineers are ready to discuss your manufacturing challenges — from initial concept to full implementation.